Help robots see in 3D with sound, even when cameras and LiDAR struggle.
This master thesis explores how Sonair’s ADAR technology can be applied to Simultaneous Localization and Mapping (SLAM) for robotic systems. The goal is to use our 3D ultrasonic sensors to build a map of an environment while simultaneously estimating the robot’s position within it.
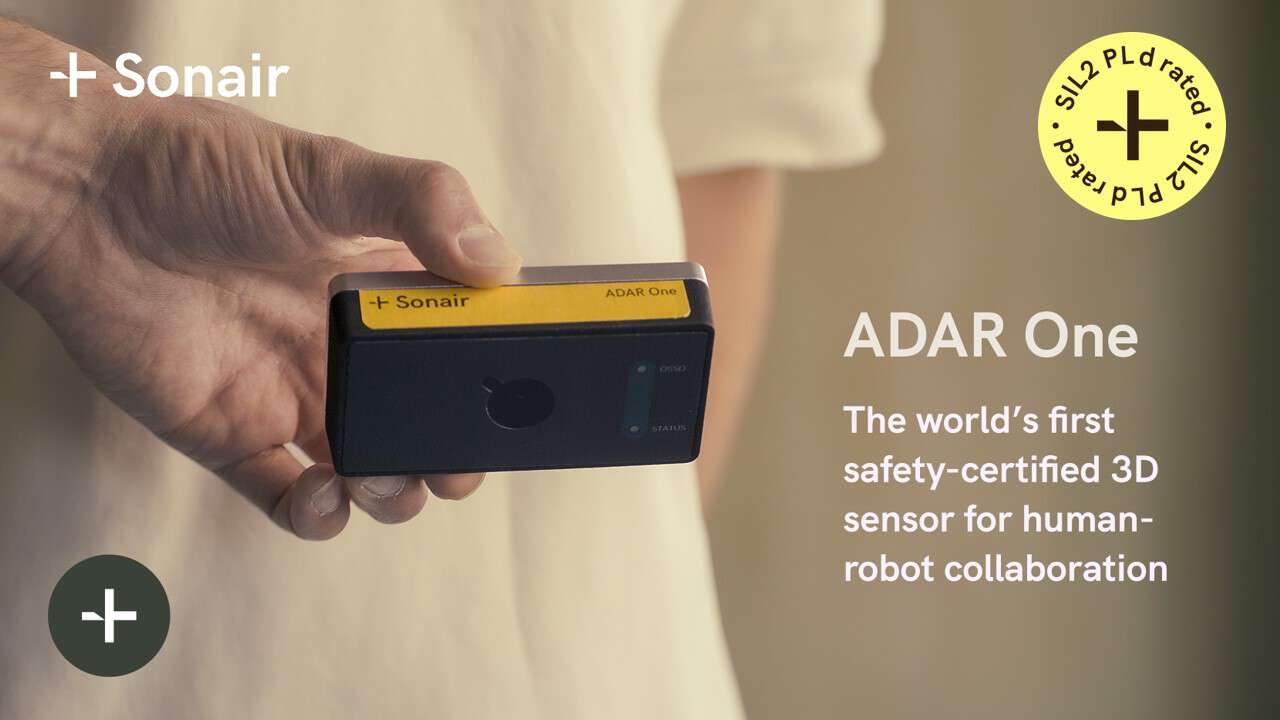
You will work hands-on with real hardware: integrating ADAR sensors on our inhouse robotic platform (Wheeltec AMR + Sonair ADAR sensors, ROS 2). Our ADAR sensors produces an acoustic 3D pointcloud of the detections in the environment. This thesis will investigating how such acoustic sensing can support robust navigation in SLAM. The project may also explore sensor fusion with IMU, camera, or LiDAR data to improve precision and reliability, and compare ADAR-based SLAM with traditional vision and LiDAR approaches in conditions where optical systems often fail, such as low light, dust, and fog.
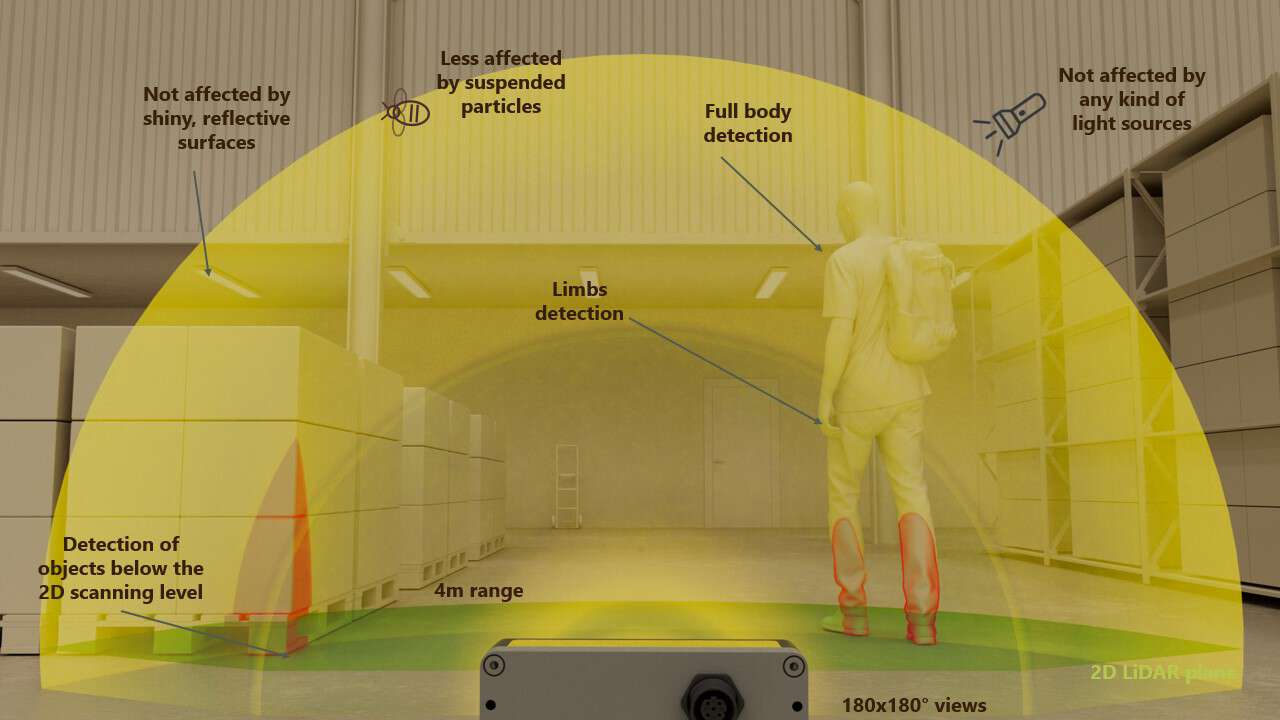
This is an opportunity to work at the intersection of robotics, signal processing, and cutting-edge sensor technology with results that could contribute to more versatile and resilient navigation systems for real-world AMRs and robots.
Demo of ADAR:
Qualifications:
Excellent grades (you are a A-B student)
Strong programming skills (Python and Git)
Self driven and creative
Strong written communication skills
Preferably some experience with ROS2 (Robot Operating System)