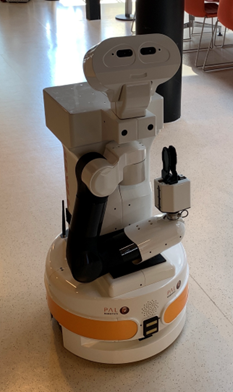
This master thesis investigates Human-Robot Interaction in a specific caregiving/care- receiving scenario. The student may choose one specific caregiving task defined in a caregiving/care receiving scenario: e.g., hand-over of an object, rising up from a seated position in a home/healthcare context. To solve the task, three different actors are or may be involved (they can interfere at any given moment): the healthcare receiver, the robot, and the caregiver. The robot should decide when it has full autonomy, or when it should change to be semi-autonomous (its autonomy its overriden by a caregiver, or by the carereceiver). The robot should be able to make decisions around its autonomy based on retrieving information from the environment (e.g., robot situational awareness, where robot situational awareness is defined as the ability to perceive elements - objects and people- in the environment, comprehend their meaning, and predict their status into the near future to make effective decisions. Levels: perception, understanding, and prediction).
Aim: create a human-robot shared autonomy model in a specific caregiving task
Research outcome: proposing a Human-Robot shared autonomy model exemplified through a specific caregiving task
Tasks:
1. Choose the caregiving/care-receiving scenario.
2. Define the scenario and the specific robot task.
3. Implement the technical part on TIAGo (or another available robot at ROBIN). You may use VLMs, LLMs to make the robot understand its environment in that specific task, and to be able to interact with the human actors.
4. Test the implemented scenario with users.
5. Write the master thesis.
Resources:
On human vs. machine autonomy: https://aisel.aisnet.org/sjis/vol34/iss2/5/
Situation awareness: https://dl.acm.org/doi/10.1145/3743693