Webpages tagged with «FPGA»

The overall goal of this project is to leverage the flexibility of FPGA architecture to test algorithms and/or control multiple motors in robotic systems.

Processors are often judged by their performance in terms of throughput, but not all applications require high throughput. At times either low power usage and less area spent on a processor may be equally or more important. One way of achieving the latter is by using serialized microarchitectures, such as in the ZPU or Serv processors.
Inventas has several options for master thesises, available to students at UiO and other institutions.
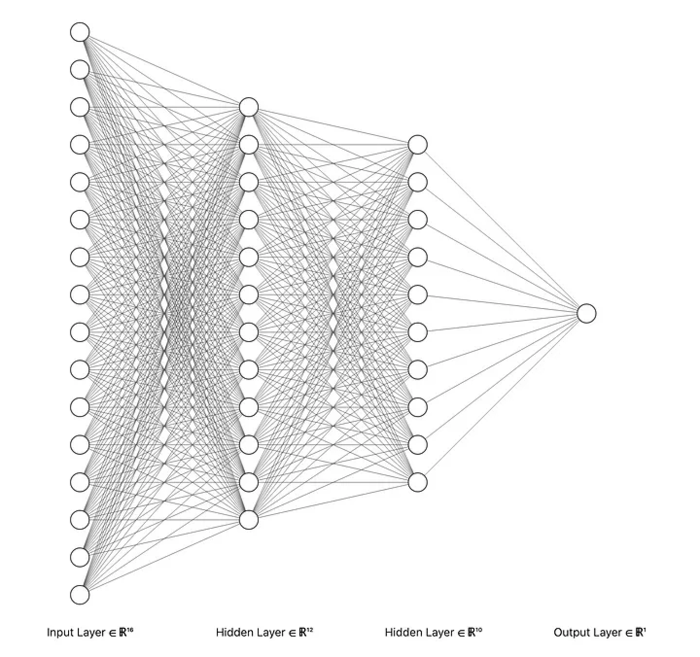
This project shall look into implementing an asynchronous spiking neural network on an FPGA.
What is the best way for a robot to tackle challenging surfaces? Prediction? Sensor data? AI processing? Parallell computing?